|
Hoang Trieu Vy LE 2025 –

I am a Research Scientist at Beink Dream in Paris, where I build the harness for end-to-end agentic AI systems. I also work on flow-based image generation and multimodal systems that keep a structured representation of 2D, 3D and CAD scenes. 2024 – 2025

I was a Research Engineer at CEA – DIGITEO Labs in Saclay, where I worked on lightweight learning models for 3D CT reconstruction — building physics-consistent scene representations from sparse, noisy measurements and limited high-dimensional observations. 2020 – 2023


My PhD at ENS Lyon was focused on variations of the Mumford-Shah functional for interface detection in degraded images, bridging proximal algorithms and unrolled deep architectures [take a look] under the supervision of Prof. Nelly Pustelnik and Dr. Marion Foare. Along the way I spent a year at UC Louvain (2020–2021) designing scalable accelerated algorithms for joint image restoration and edge detection on large-scale physics experiment images. I also taught Introduction to Machine Learning and Optimisation at EPITA, and Machine Learning & Optimization hands-on courses at ENS Lyon. 2015 – 2020

I studied at INSA Toulouse where I earned my Master of Engineering in Applied Mathematics, majoring in Mathematical Modelling and Numerical Analysis. |
|
Research Interests
|
Recent Works |
|
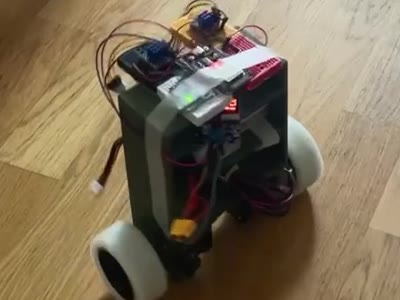
Zingu — a two-wheeled self-balancing robot
A two-wheeled self-balancing robot that picks itself back up after a fall. I'm building it toward an outdoor companion: the robot-dog idea on two wheels, smarter, and open to whatever task I can imagine giving it. Zingu Brain — the perception and decision side — comes next. [Project] [Code] |
|
Gist
|
Gist
Ongoing research on scene understanding through many senses at once. Humans take in vision, touch, sound, a sense of space and a sense of time, and fuse them into thought and reasoning. Sometimes we even dream. Models cannot, and Gist is my attempt to build a multimodal system that perceives, reasons, and maybe one day dreams. |
|
Meepo
|
Meepo
A personal AI assistant. [Code] |
Publications |


Ph.D Thesis |

Talks |
|
EUSIPCO, Belgrade, Serbia, Aug 2022
Conference on Digital Geometry and Discrete Variational Calculus, Mar 2021 |
Teaching |
|
Introduction to Machine Learning and Optimisation, EPITA
Machine Learning and Optimization hands-on courses at ENS Lyon |
For FunPolyverse — a hobby game I build on weekends. A low-poly 3D real-time strategy game in Godot, where time has shattered into crystal shards and each shard is one frozen age of civilization. |